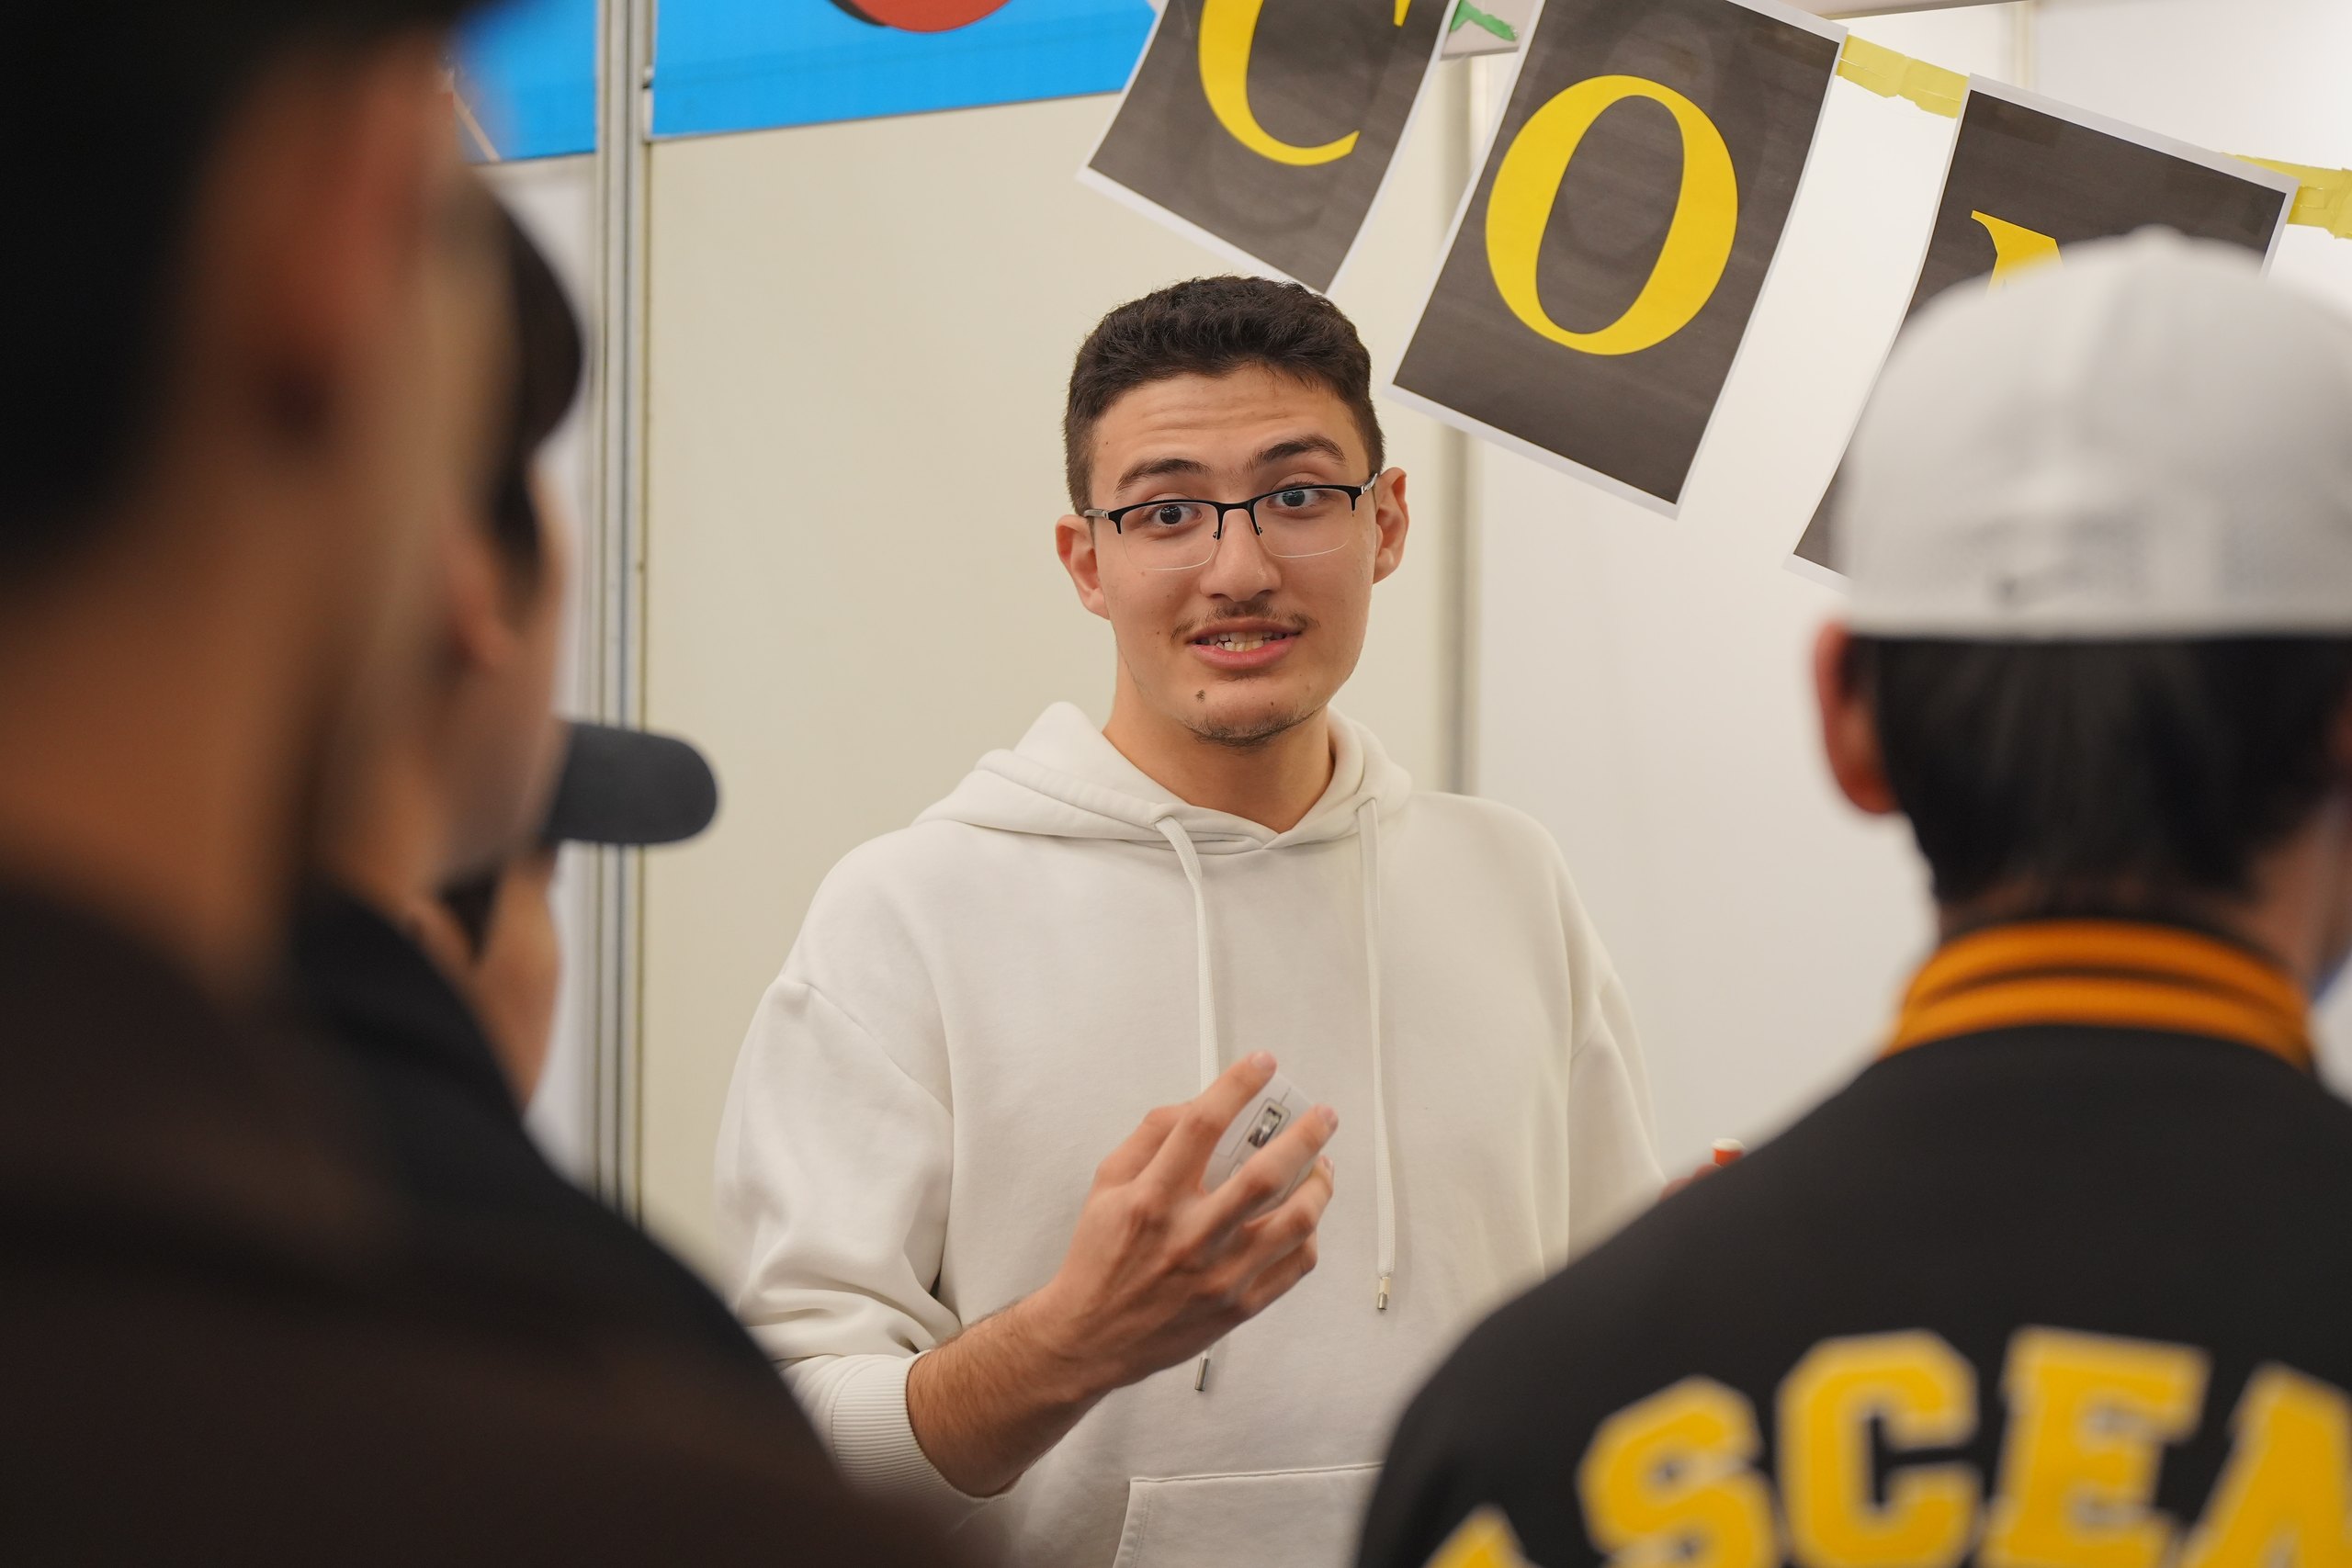
Abdullah mid-sentence with a microphone at an exhibition booth, hands moving as he explains something.
Abdullah alone on a floodlit sports field in heavy snow at night, arms spread wide, his footprints leading back across the pitch.

ABDULLAH

AL MULQI

Mechanical + Electrical Engineering · KAIST, Daejeon · Robotics research intern at the FAIR Lab

I am a robotics engineer specializing in autonomous systems. Utilizing perception, navigation, and control to complete missions and tasks.

Scroll
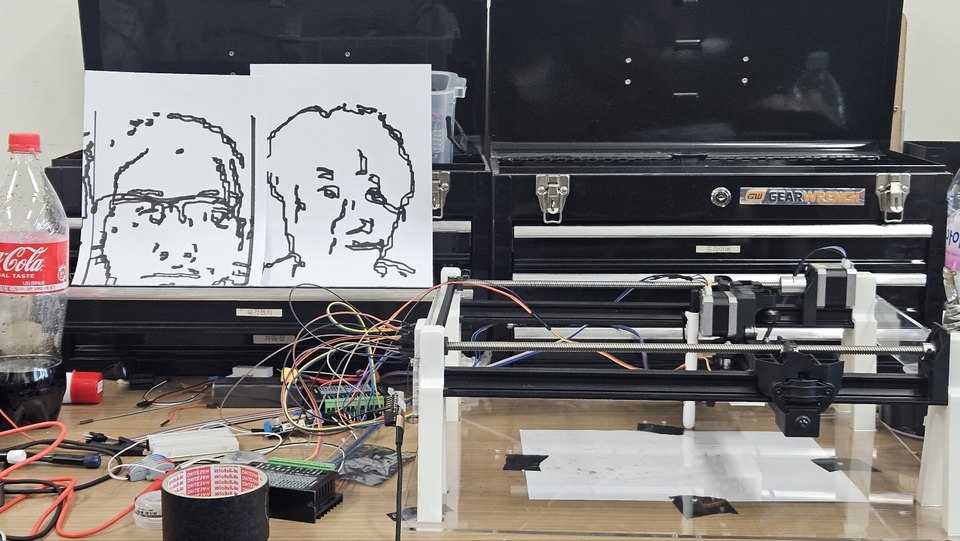
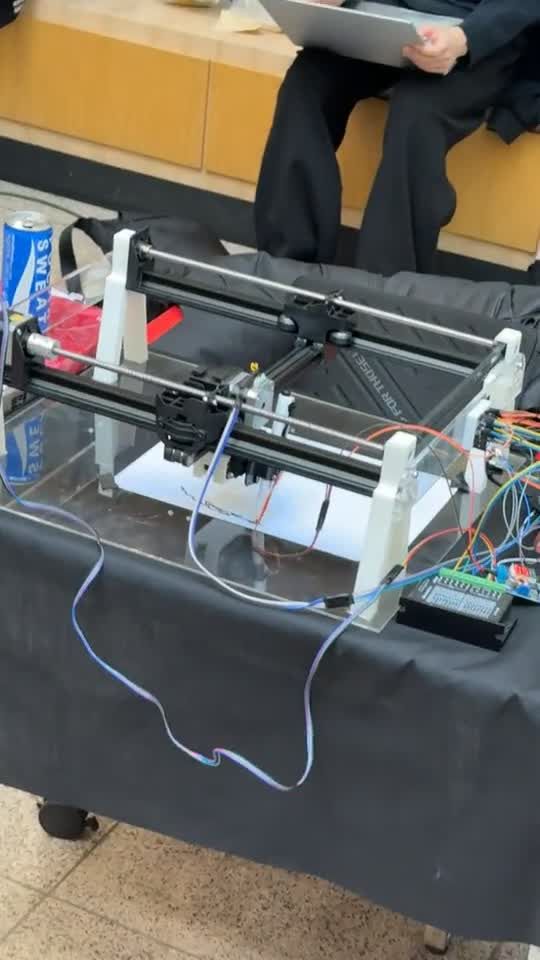
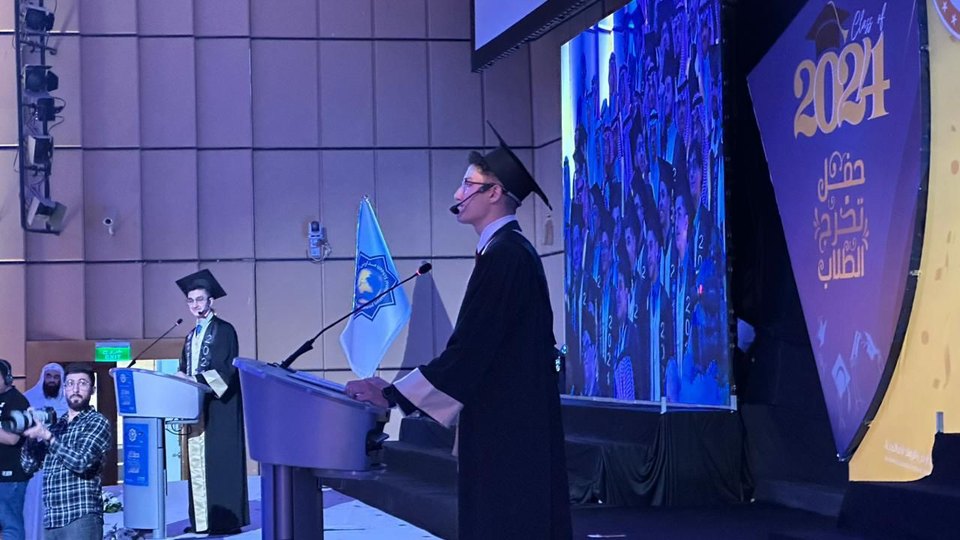
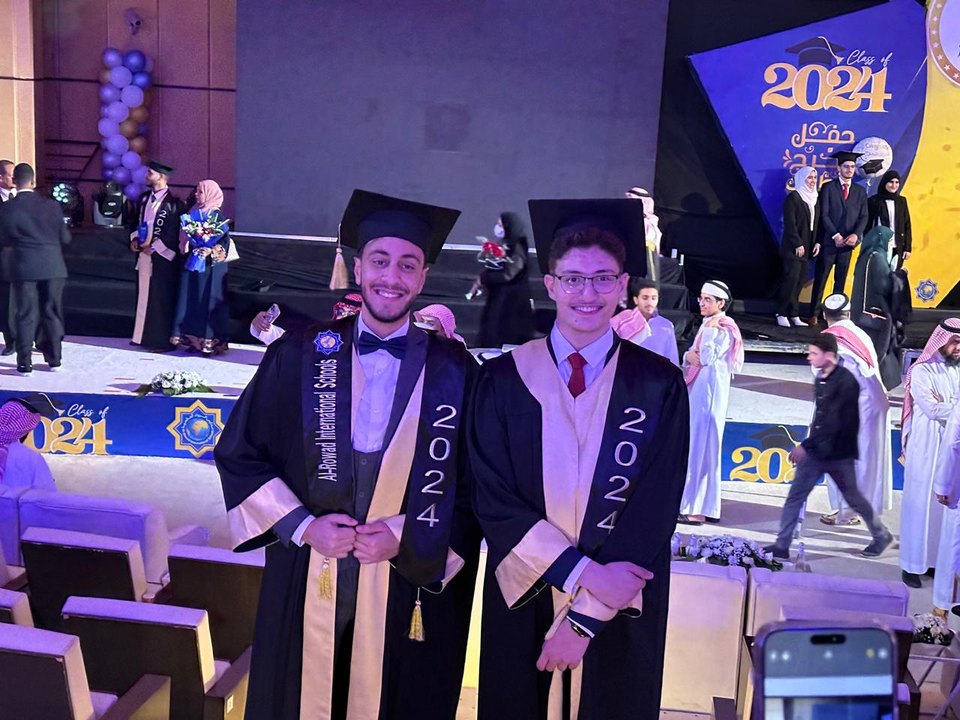
Abdullah alone on a floodlit sports field in heavy snow at night, arms spread wide, his footprints leading back across the pitch. Abdullah in cap and gown with a 2024 sash and a headset microphone, hosting his own graduation ceremony. Abdullah sitting on a rock at a mountain summit beside a stone marker, deep blue sky behind him. Abdullah copying the pose of a painted warrior statue at the gate of a Korean palace. Abdullah in front of a waterfall on a rocky hillside. A student smiling and holding up a line-drawn caricature of his own face, drawn by the machine. Abdullah sitting cross-legged on a Korean throne in front of a red and gold backdrop. Abdullah and friends on a blue-lit stage during a performance. Abdullah and two friends sitting in front of a large aquarium tank. Cherry blossom branches lit from behind by a low sun. Abdullah and a friend grinning back at the camera from cinema seats. Abdullah on a mountain boardwalk with a cliff face and forest behind him. A steep street stairway painted in rainbow stripes and lined with shopfronts. Snow falling through the beam of a floodlight at night.
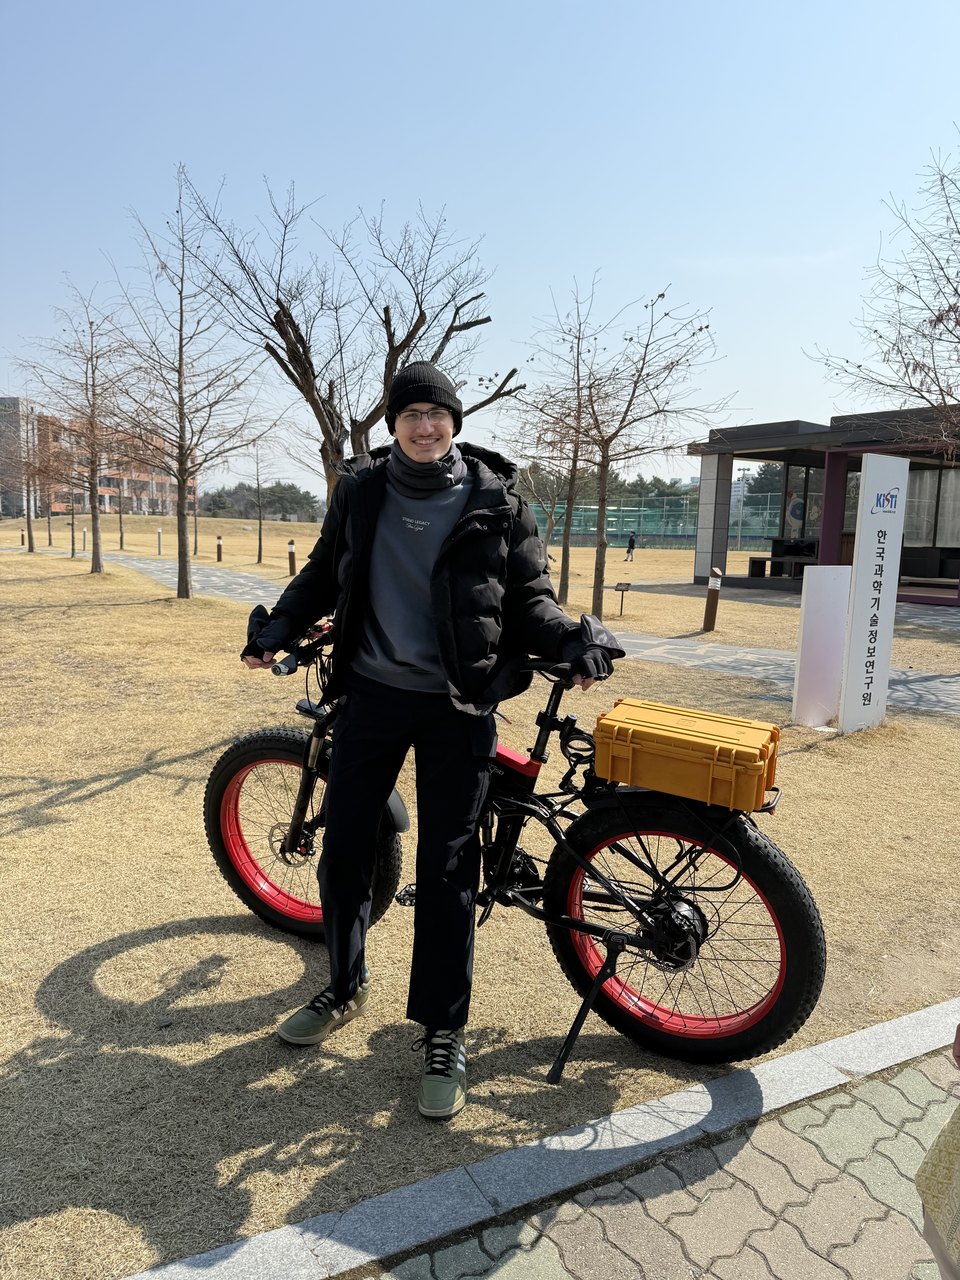
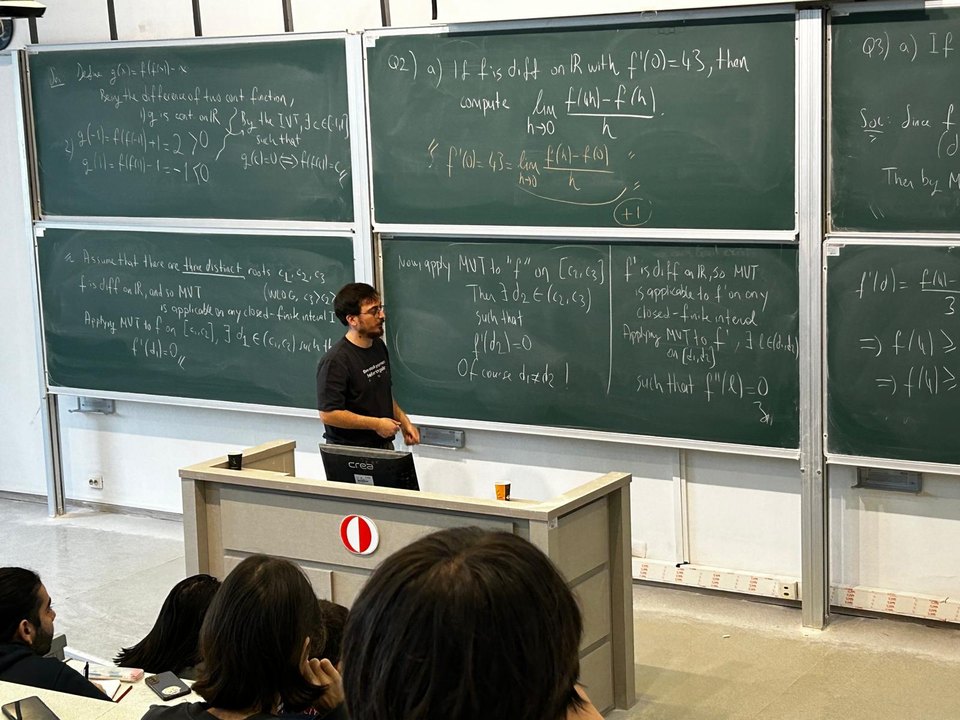
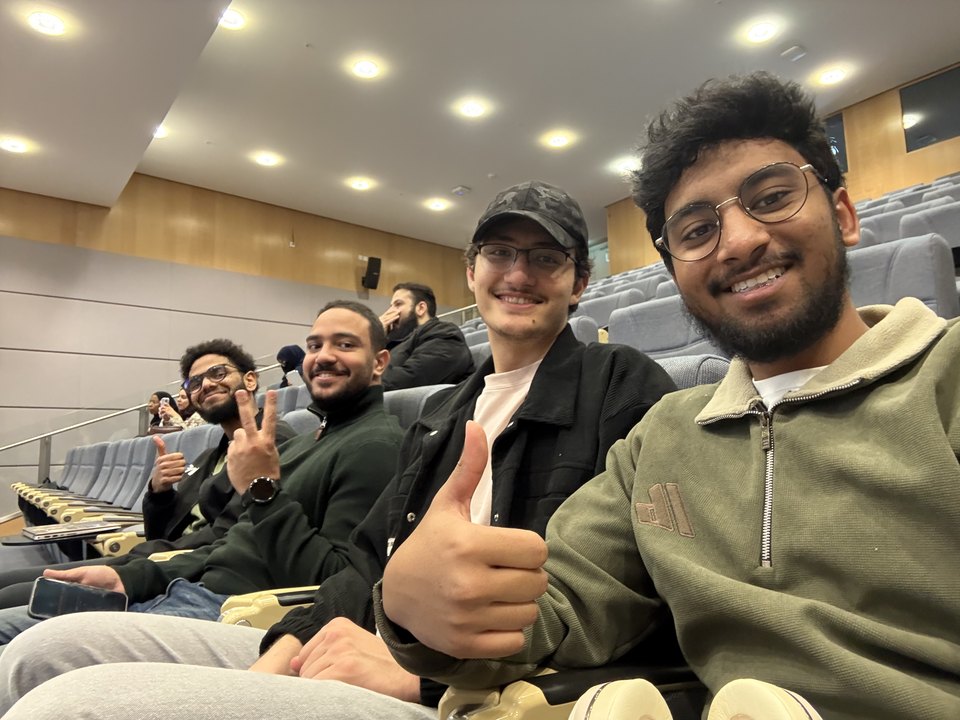
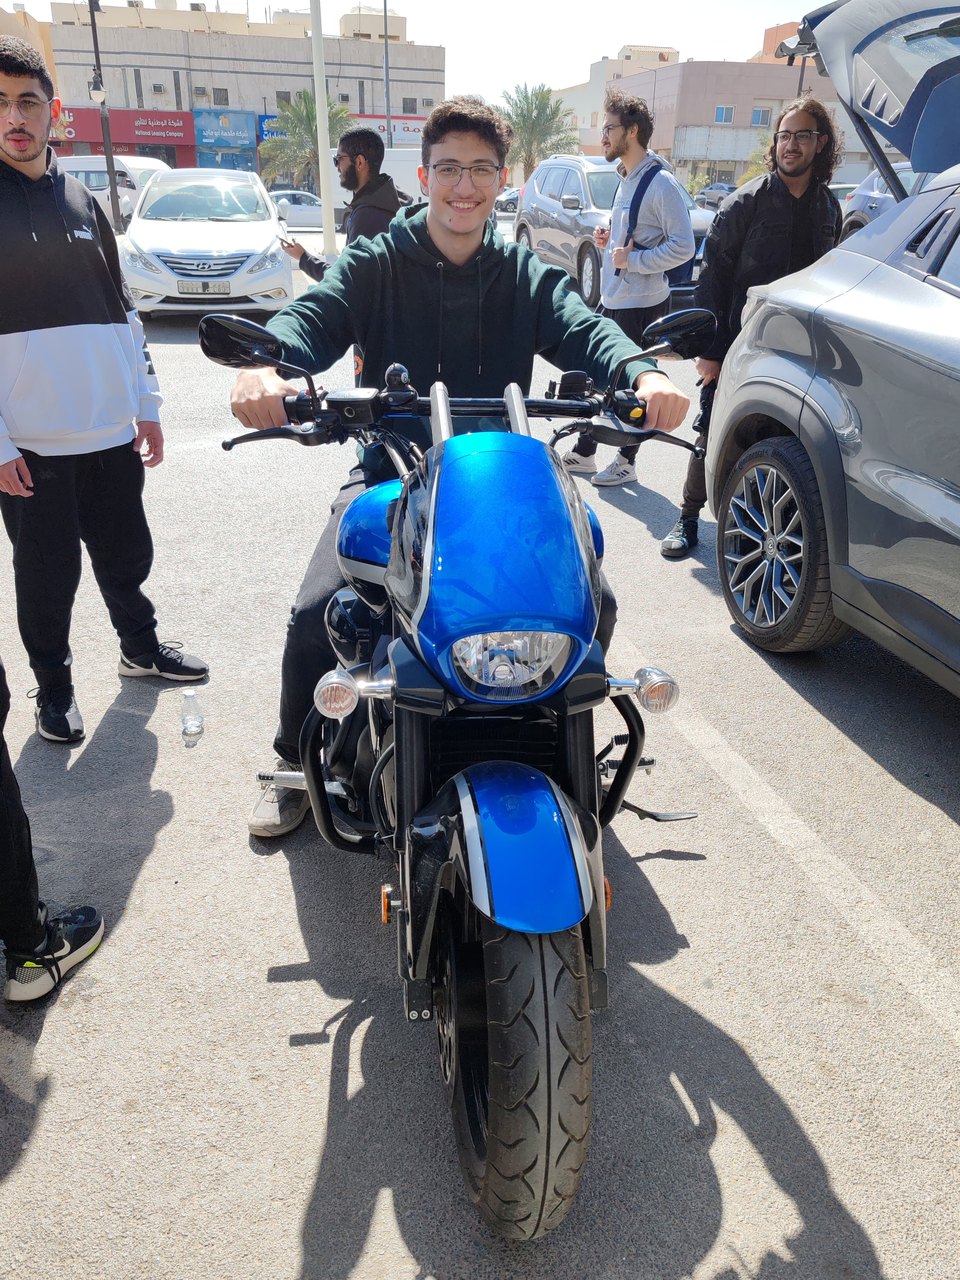
Abdullah and a classmate on stage in graduation robes, both wearing 2024 sashes. Abdullah standing with his fat-tyre e-bike on a campus path in winter. A lecture theatre at ODTU with three blackboards covered in handwritten analysis proofs, the lecturer at the podium. Abdullah and four friends in a lecture hall, thumbs up and peace signs at the camera. Abdullah sitting on a blue motorbike in a sunlit street with friends standing around. Abdullah leaning back against a railing at night with a lit city behind him. A beach at sunset with the tide running out, low sun across the water. A Korean palace gate with visitors in hanbok crossing the courtyard. A tall tower lit green at night above a glowing shopping complex. A red and blue arch bridge over a riverside path. Abdullah and two friends in hanbok outside a rental shop. A ginkgo tree in full yellow against a clear blue sky. A cat sitting on a tiled floor, looking up at the camera.

Currently

Updated October 2026

ROBONEXUS

Project lead

Through to the next stage. The competition is now in March 2027.

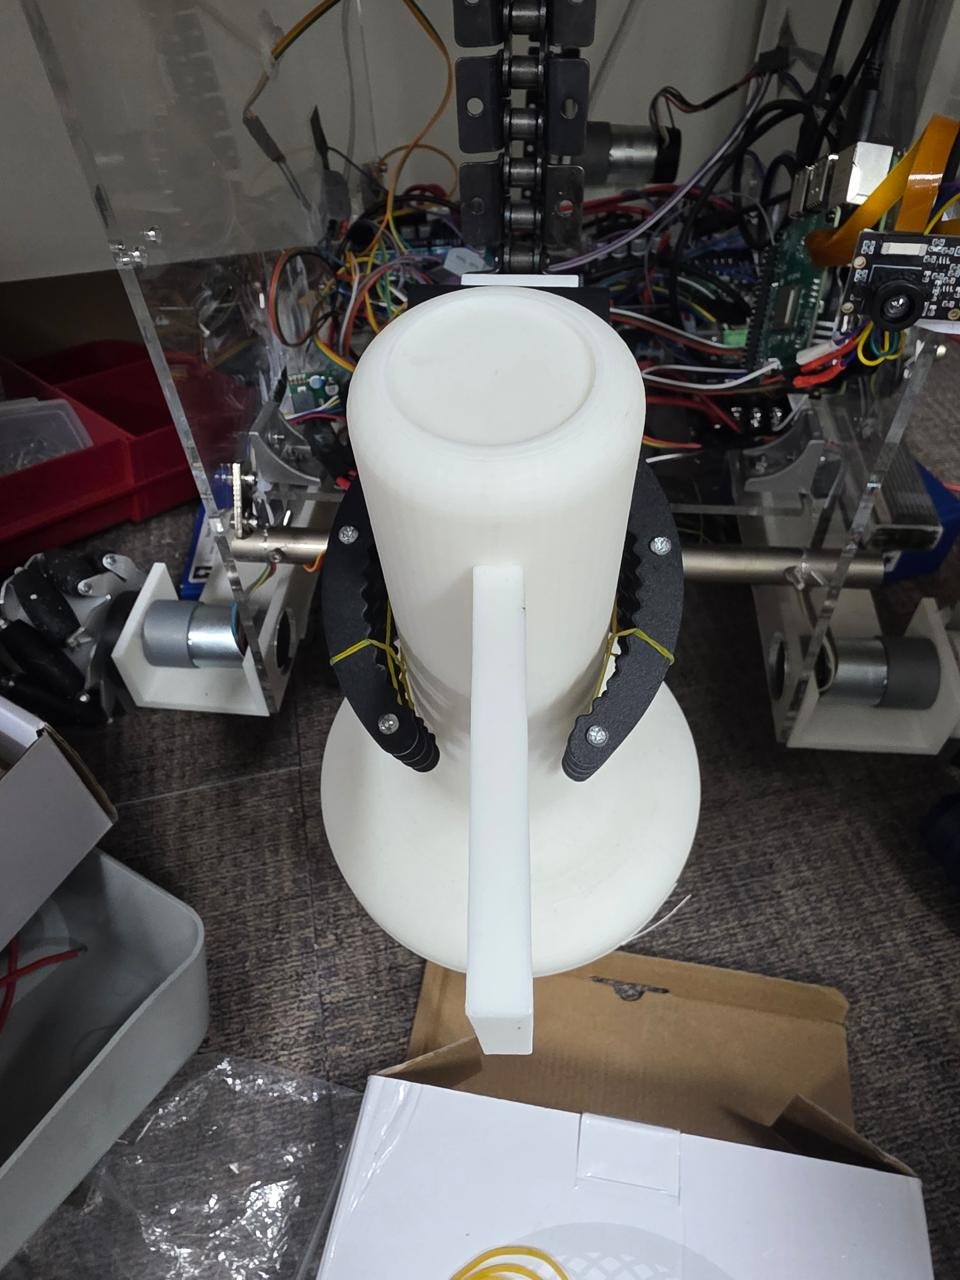
A capture-the-flag robot that plays the first 45 seconds of every match on its own.

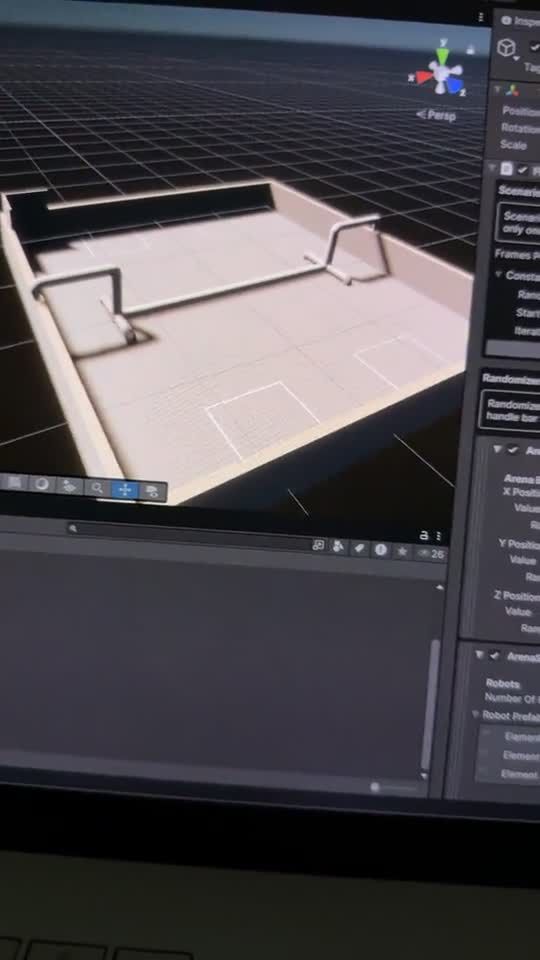
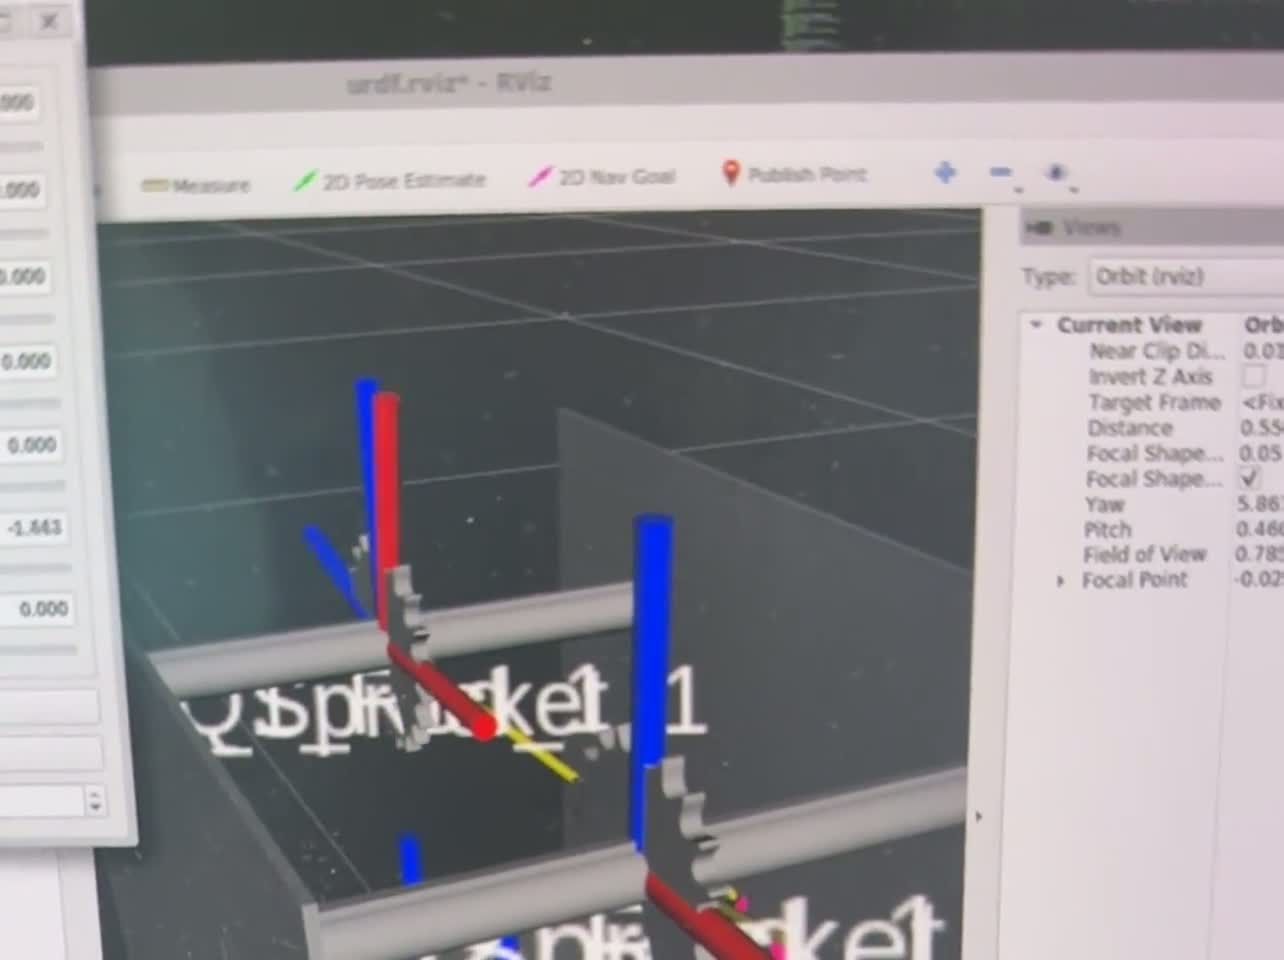
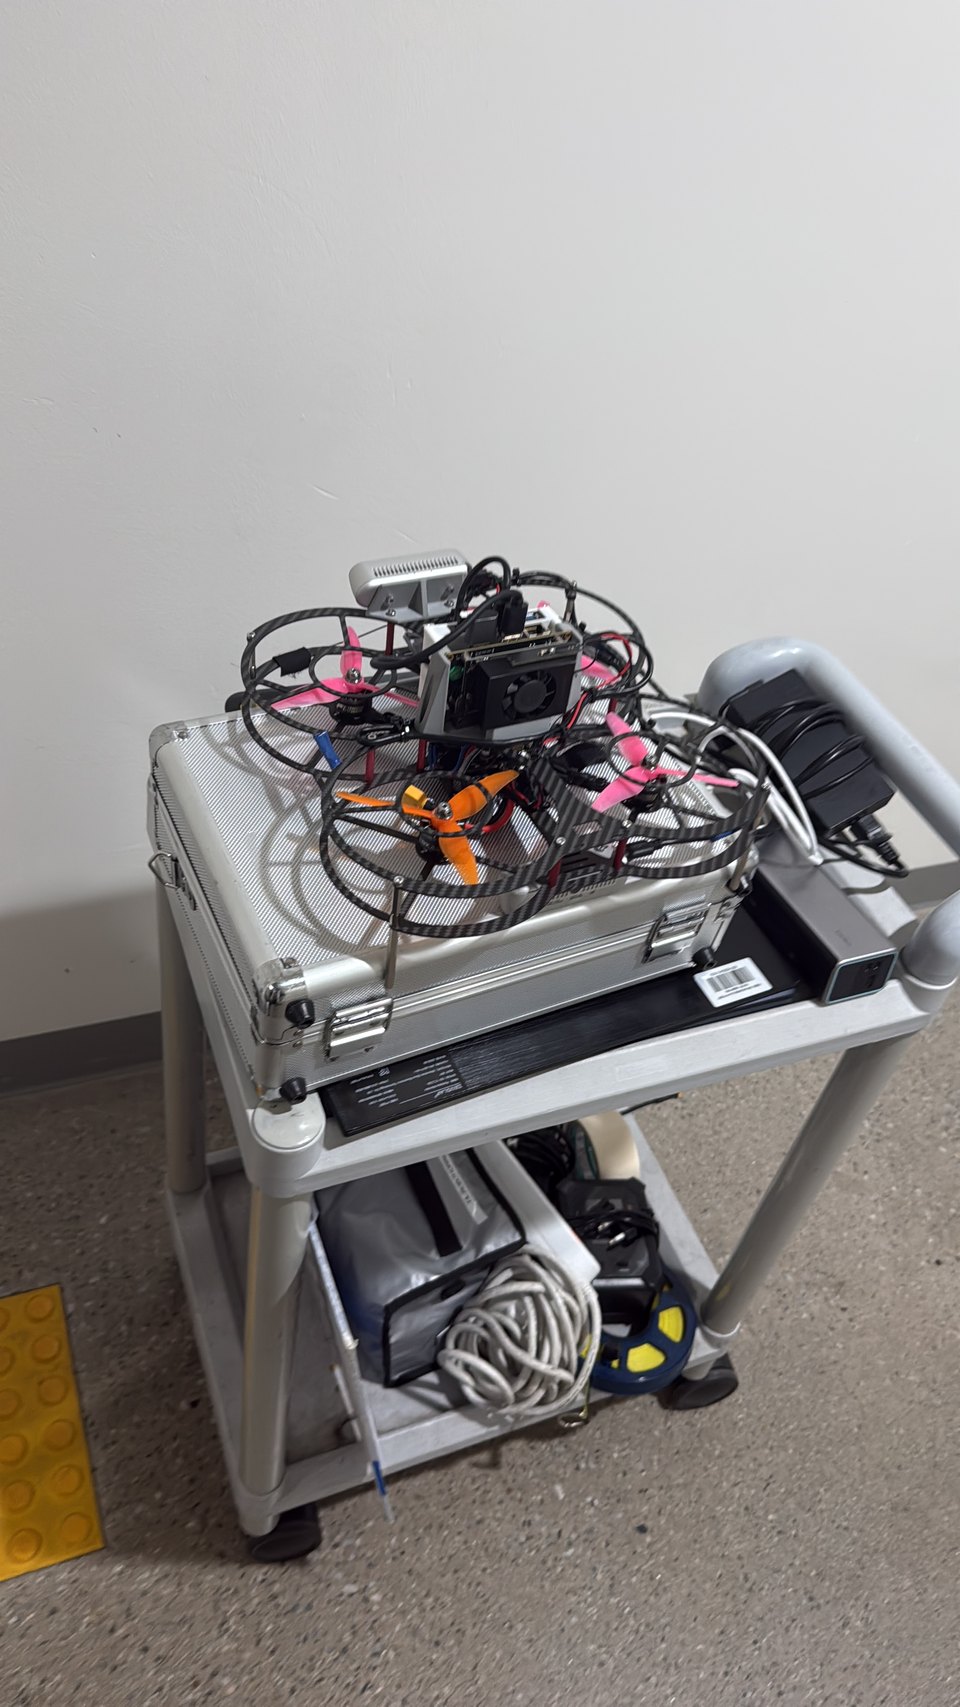
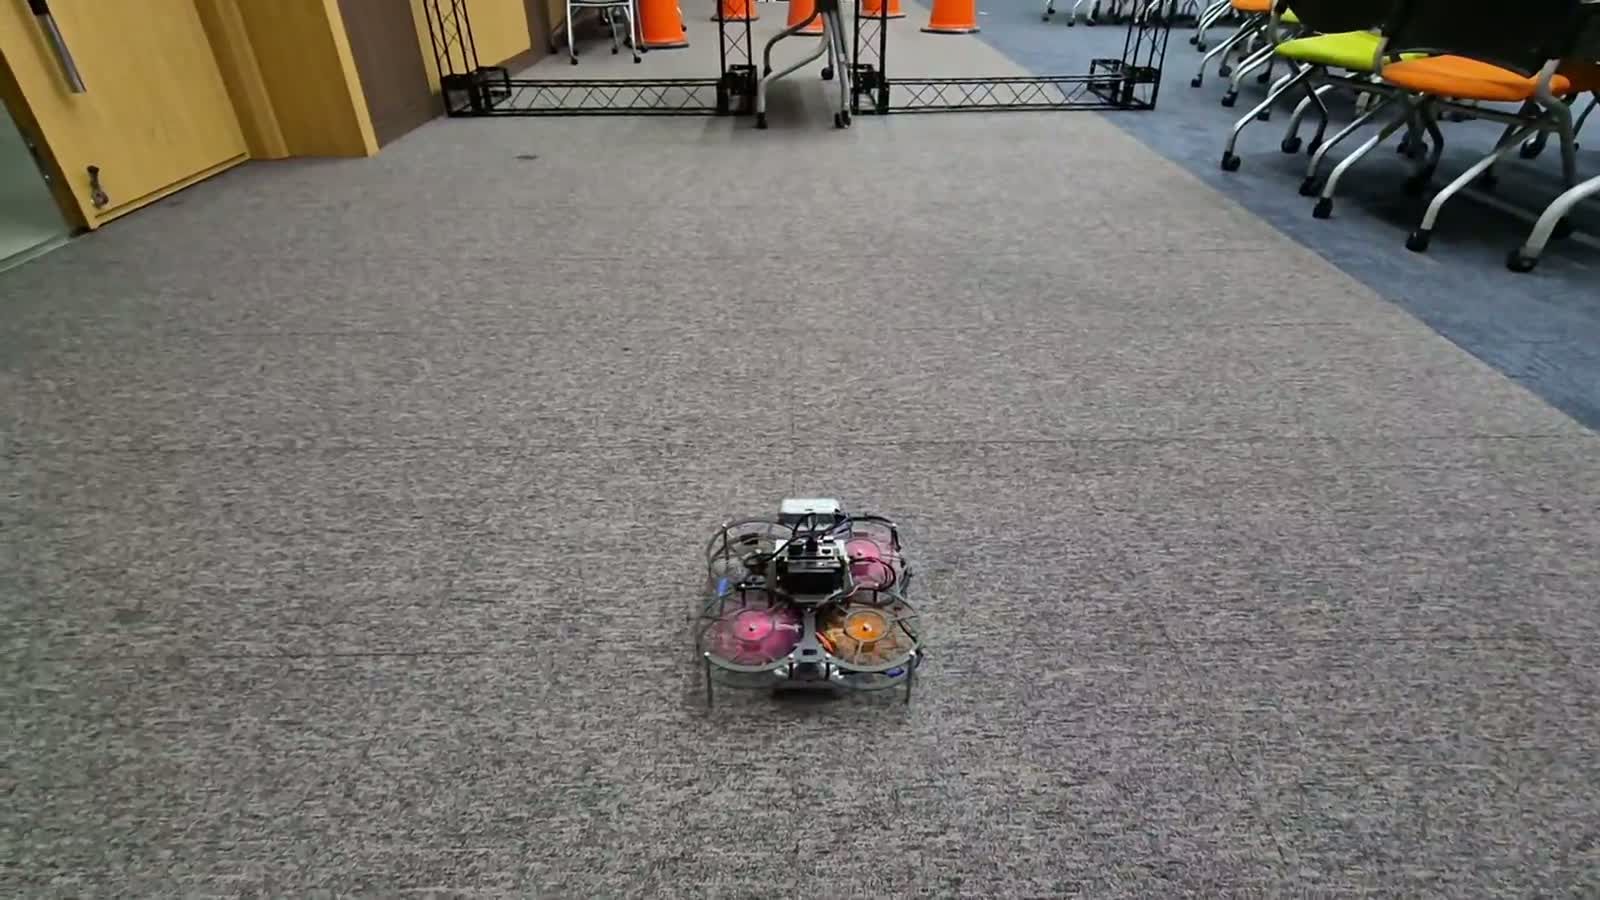
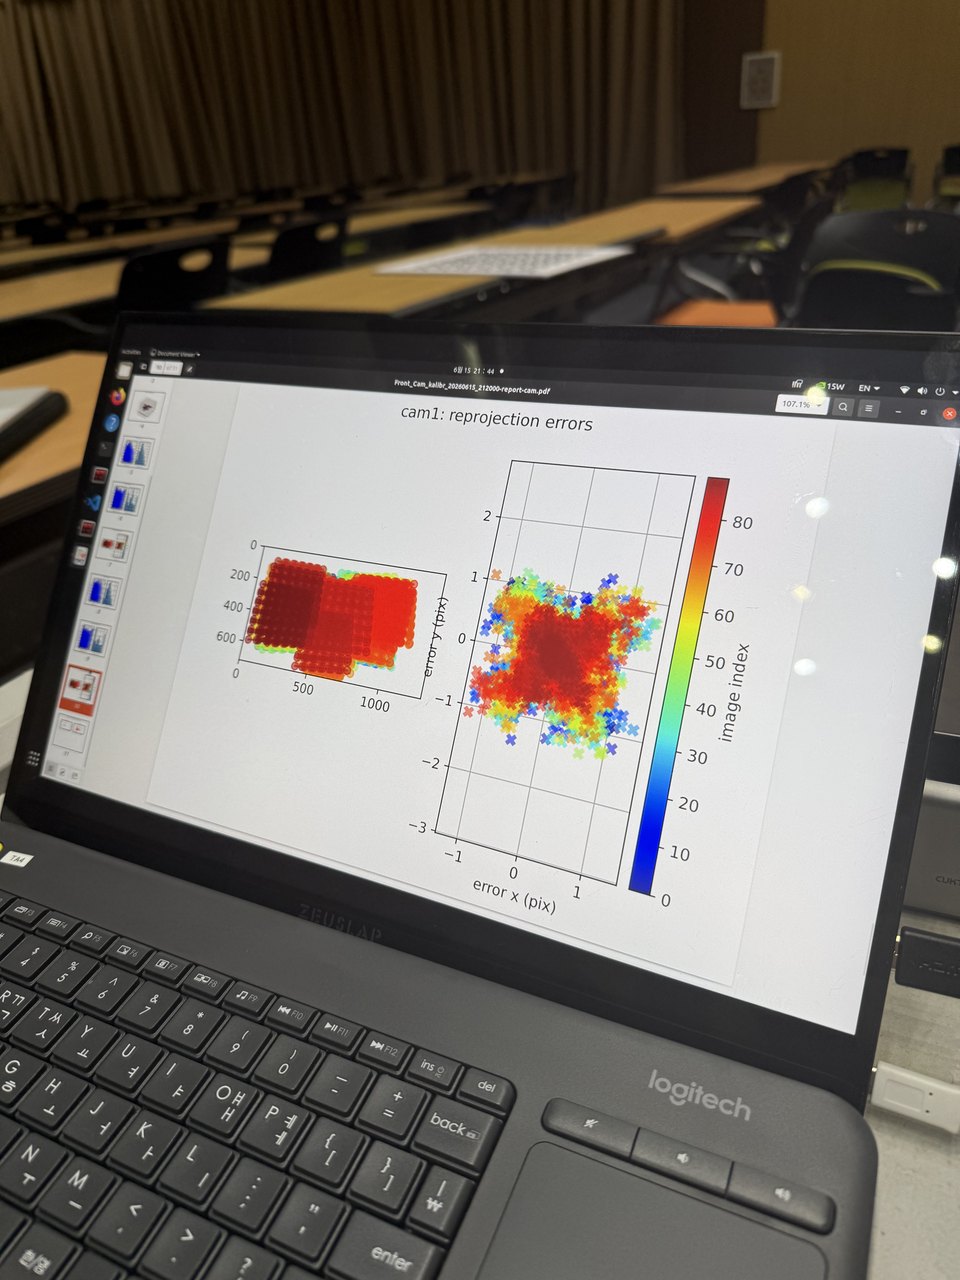
The first prototype is built and driving. Every motor and both grippers are programmed, and the robot tracks its own position with OpenVINS visual-inertial odometry from a stereo camera and IMU, calibrated with Kalibr. I designed the robot and its URDF, built the Gazebo simulation it was developed in, and raised ₩6,000,000 to fund it.
Next Moving the mission-control code and motion planner from the simulation onto the robot, starting the second robot, and ordering sheet metal for the competition build.

Team
KAIST Micro-Robotics club
Localization
OpenVINS, stereo camera + IMU
Calibration
Kalibr
Funding
₩6,000,000
First drive on its mecanum wheels
One of the robot's grippers clamped around a white competition flag, wiring and the chain drive visible behind it.
A gripper closed on a competition flag

FAIR Lab

Research intern

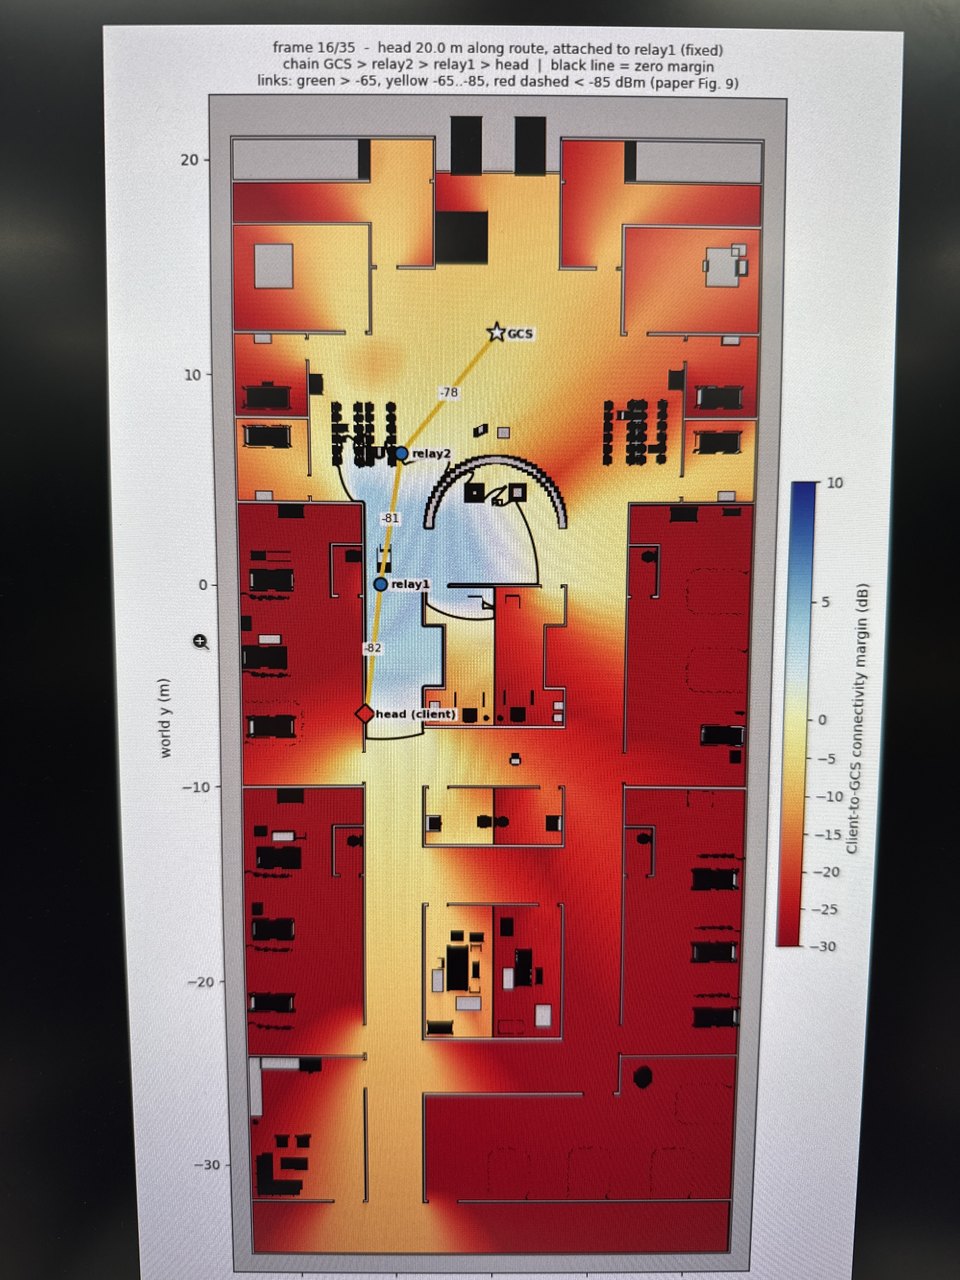
Keeping a robot connected as it drives deep into a building, using other robots as radio relays.

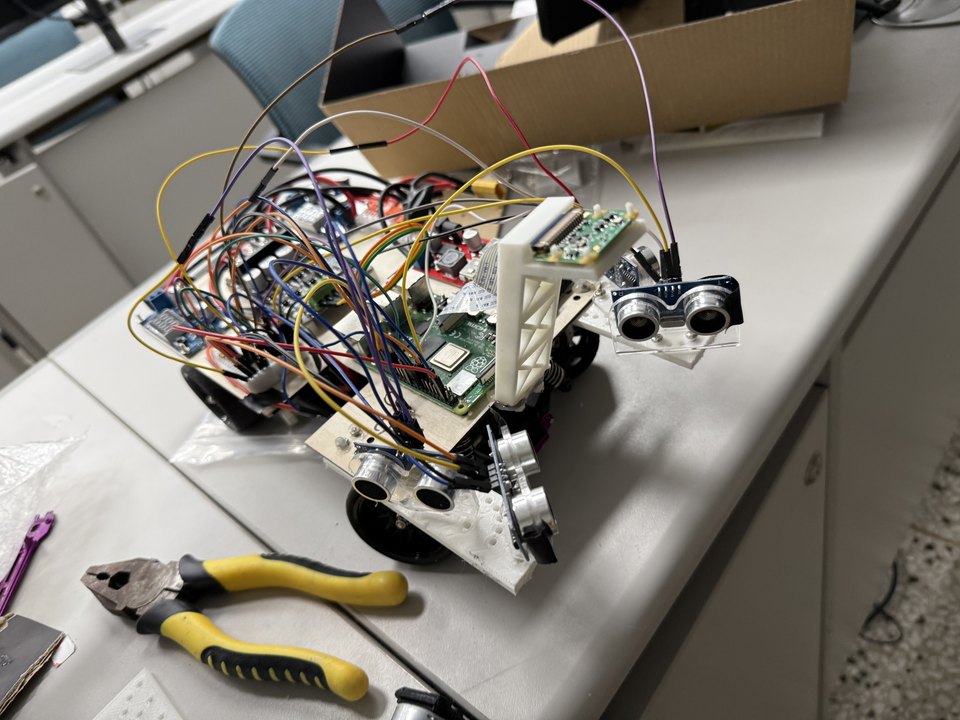
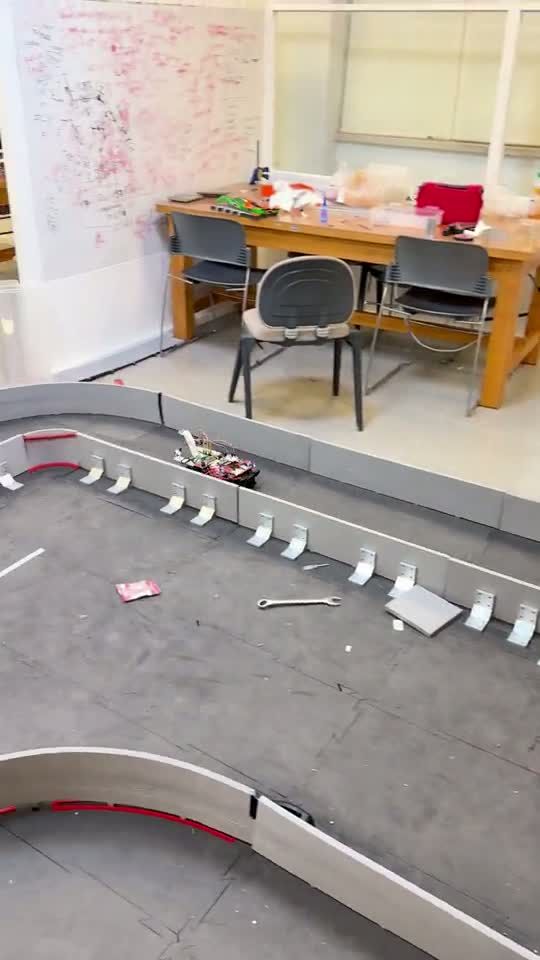
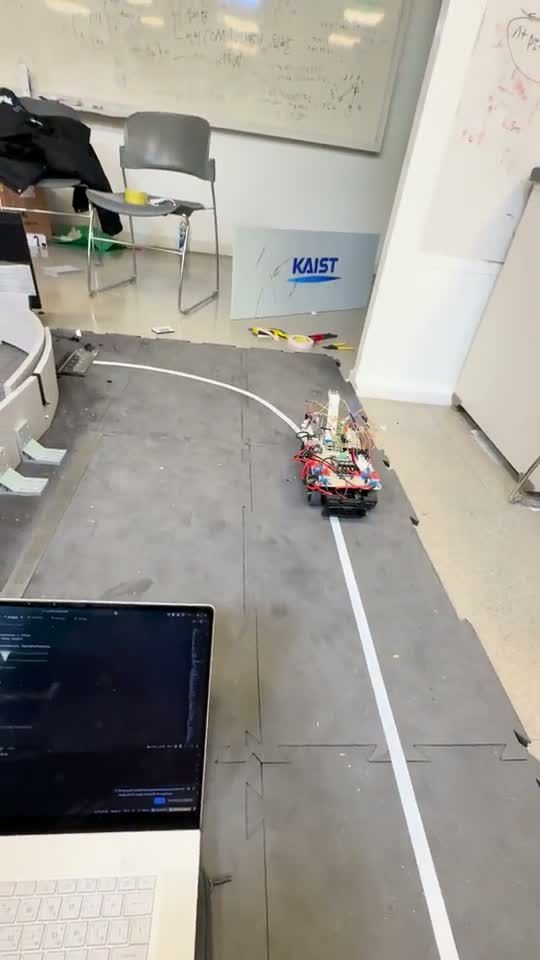
I set up a Rajant Cardinal mesh network, with Ackermann cars as the relays and the lab’s chain robot as the client. I programmed an obstacle-aware model of signal strength (RSSI), calibrated it against our own radios, and tested it on a hospital floor I imported into Gazebo. Getting the chain robot and the relays into one simulation meant bridging mismatched ROS and Gazebo versions; the relays now reach their waypoints to within 2–8 cm.

Next Making the relays move on their own, following the signal strength to keep the client connected.

Lab
Field AI and Robotics, KAIST
Radios
Rajant Cardinal mesh
Robots
Chain robot client, two Ackermann relays
Stack
ROS 2, Gazebo, Docker on two NUCs
Relays trailing the client through the simulated hospital
A connectivity-margin map of a hospital floor plan, red where the signal fails and blue where it holds, with the relay chain drawn from the ground station to the client.
Where the link holds (blue) and drops (red)

Angel Robotics

Intern & hackathon

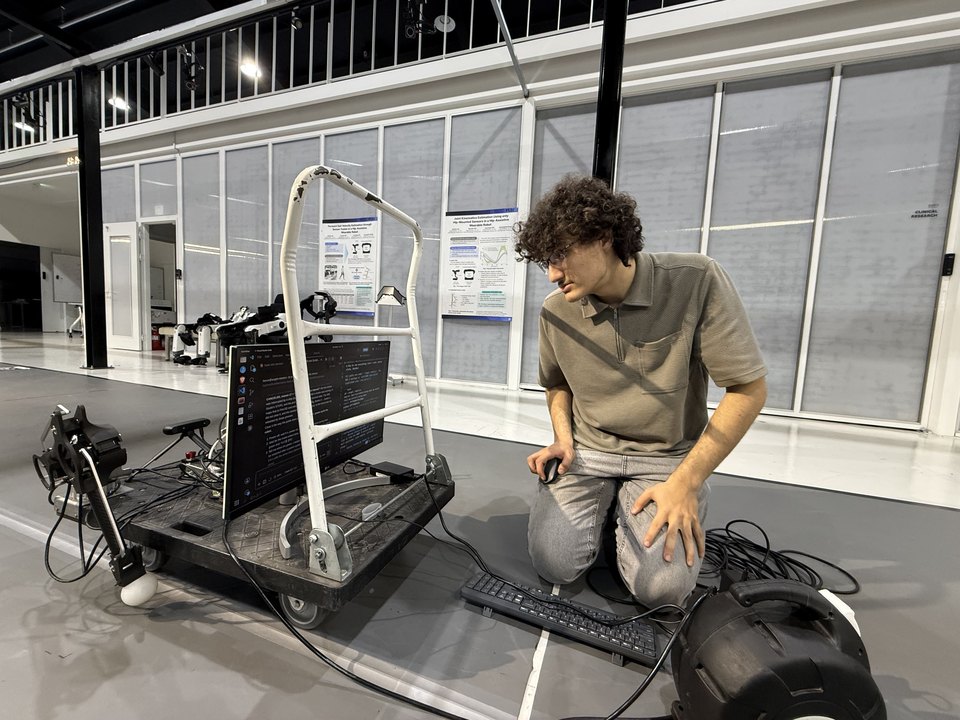
A two-armed robot on a cart that gets around by pushing the floor with its arms.

One month, a team of three, and hardware that had barely left the lab: Angel Robotics’ new PHACT actuators, which cancel their own friction in real time so the joint delivers clean, measurable torque, driven from an NVIDIA Jetson AGX Orin with 64 GB of memory. I worked on the design, assembly and programming: I built the arm’s URDF from CAD, taught its motions by imitation learning, and paired the robot with SLAM, using Orbbec depth cameras and NVIDIA’s cuVSLAM, to explore and map the space around it. Angel Robotics recognized me for giving the most feedback on their hardware.

Compute
NVIDIA Jetson AGX Orin, 64 GB
Actuators
Angel Robotics PHACT
Vision
Orbbec depth cameras, cuVSLAM
Team
Three, one month
Pushing off the floor
Moving the cart
Kneeling beside the dual-arm cart on the hackathon floor: two arms bolted to a flatbed trolley, a monitor and keyboard on the deck.
On the hackathon floor

EE405

Course project

A rover with an arm that finds blocks, picks them up, and drives itself through a course.

A mecanum-wheeled rover with a six-axis arm. The arm locates blocks by their ArUco markers and grasps them using forward and inverse kinematics. The rover maps the course with SLAM, then drives it with Nav2, which I retuned for its mecanum wheels: omnidirectional MPPI control, A* planning, and a speed cap hidden in the velocity smoother lifted from 0.26 to 0.6 m/s.

Course
AI & Vision for Robotics, Electronics Design Lab
Robot
Hiwonder JetRover, six-axis arm
Perception
ArUco markers, FK/IK grasping
Navigation
SLAM, Nav2 with MPPI and A*
Grasping an ArUco-tagged block
Driving the course on its own
  • KAIST — Mechanical + Electrical Engineering, expected Feb 2029
  • Micro-Robotics club (MR) since March 2025
  • KAIST Ambassador — presented KAIST back home in Saudi Arabia

What I work with

Used on shipped builds

Robotics & autonomy

  • ROS 1
  • ROS 2
  • Gazebo
  • URDF / xacro
  • SLAM
  • Visual-inertial odometry (OpenVINS)
  • EKF sensor fusion
  • Nav2 (MPPI, A*)
  • PID control
  • TF
  • Forward / inverse kinematics
  • Imitation learning
  • Mesh networking (Rajant)

Perception & ML

  • PyTorch
  • YOLO
  • OpenCV
  • Stereo depth
  • AprilTag
  • ArUco
  • Camera–IMU calibration (Kalibr)
  • Synthetic data (Unity Perception)
  • ONNX
  • TensorRT

Programming

  • Python
  • C
  • Bash
  • NumPy
  • Pandas
  • React

Hardware

  • Jetson Orin
  • Raspberry Pi 5
  • Hailo-8 AI HAT
  • ESP32
  • Arduino
  • RealSense depth cameras
  • Stepper & servo drive
  • PX4 / MAVROS

Design & tooling

  • SolidWorks
  • Fusion 360
  • Linux
  • Docker
  • Git
  • Unity

Also

  • Networking
  • Self-hosted servers
  • Video editing
  • PC building

Before KAIST

Oct 2024 - Jan 2025 · Türkiye

Ankara

One semester at Middle East Technical University, in a language and a city I did not know.

  • Electrical Engineering, ODTÜ
  • GPA 3.55 / 4.0 — High Honours
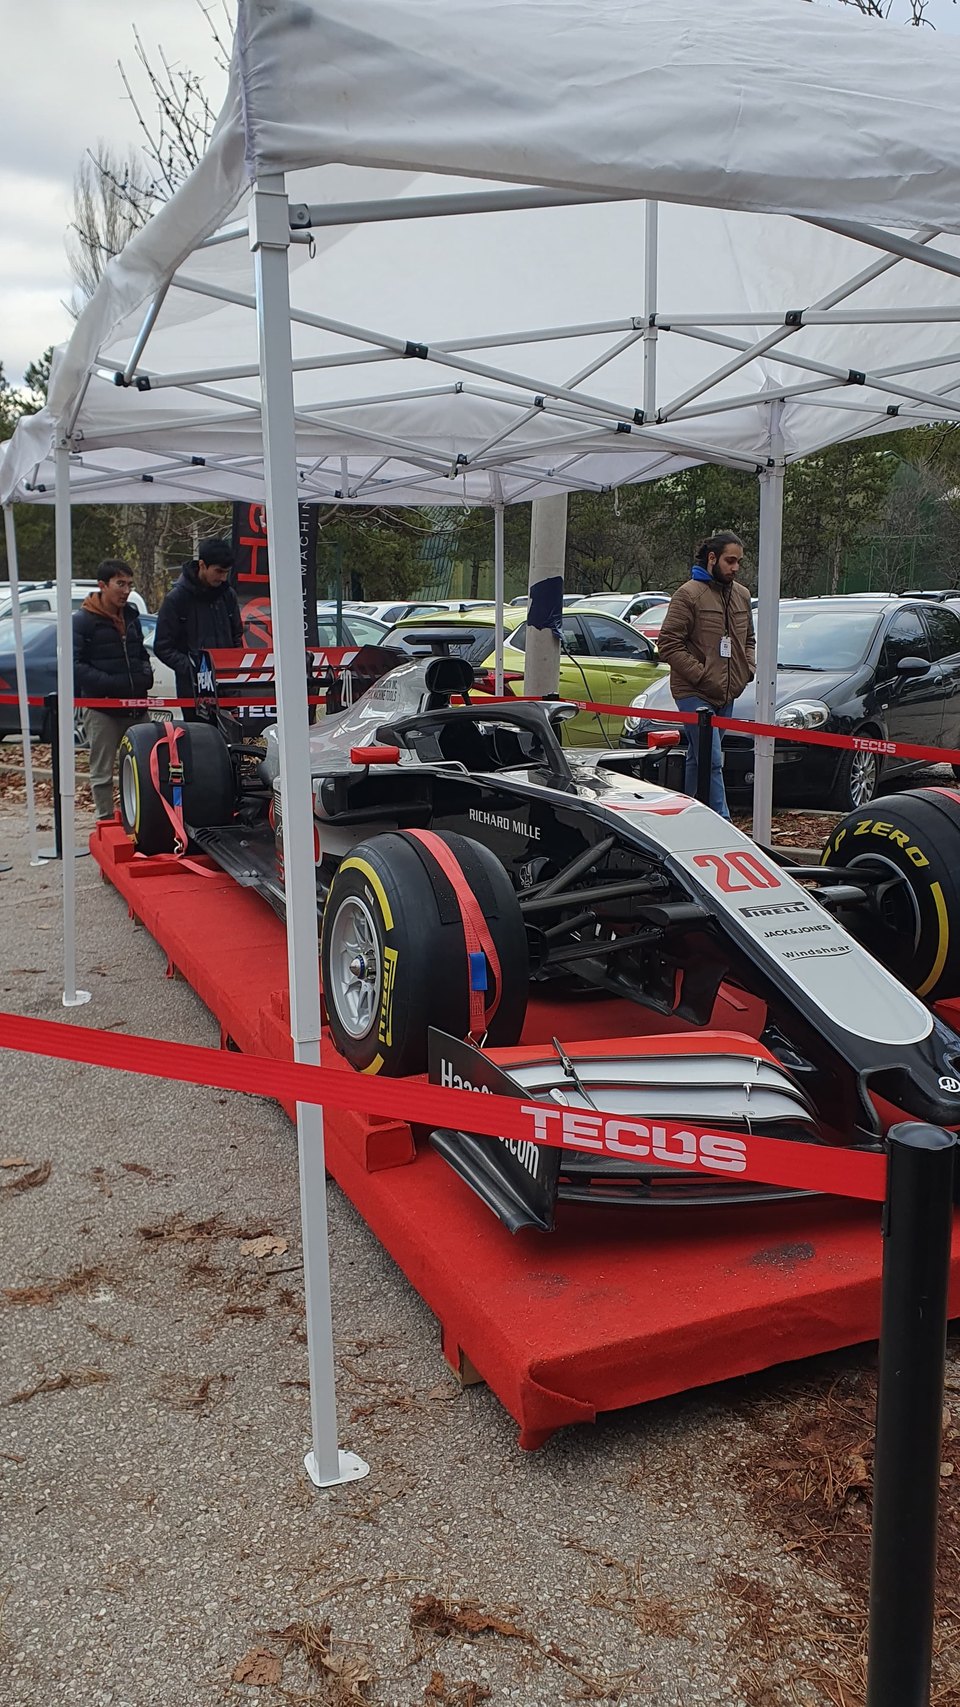
A lecture theatre at ODTU with three blackboards covered in handwritten analysis proofs, the lecturer at the podium. A Formula 1 car on a red display ramp under a marquee on the ODTU campus. Abdullah and six friends around a restaurant table in Ankara, a large mural behind them. Abdullah and three friends crowded into a selfie in an Ankara metro station.

to 2024 · Saudi Arabia

Riyadh

School, and the first things I built for other people rather than for myself.

  • Valedictorian, ranked 1st in the graduating class
  • Highest mark in the world, AS-Level Chemistry
  • Highest mark in Saudi Arabia, A-Level Physics
  • Founded the school’s first student club, and ran its PC-building workshops
  • Hosted the graduation ceremony to an audience of over a thousand
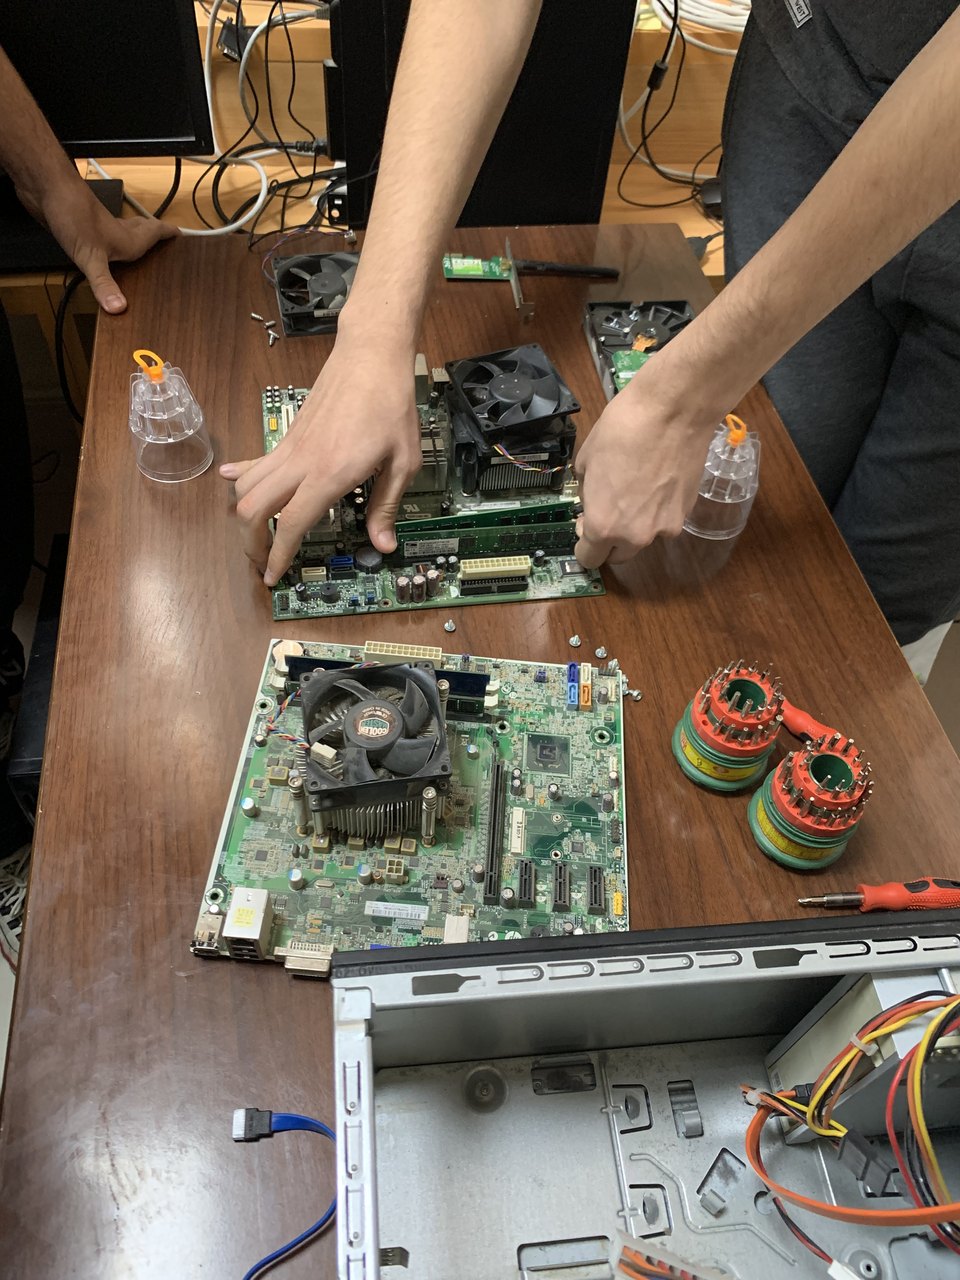
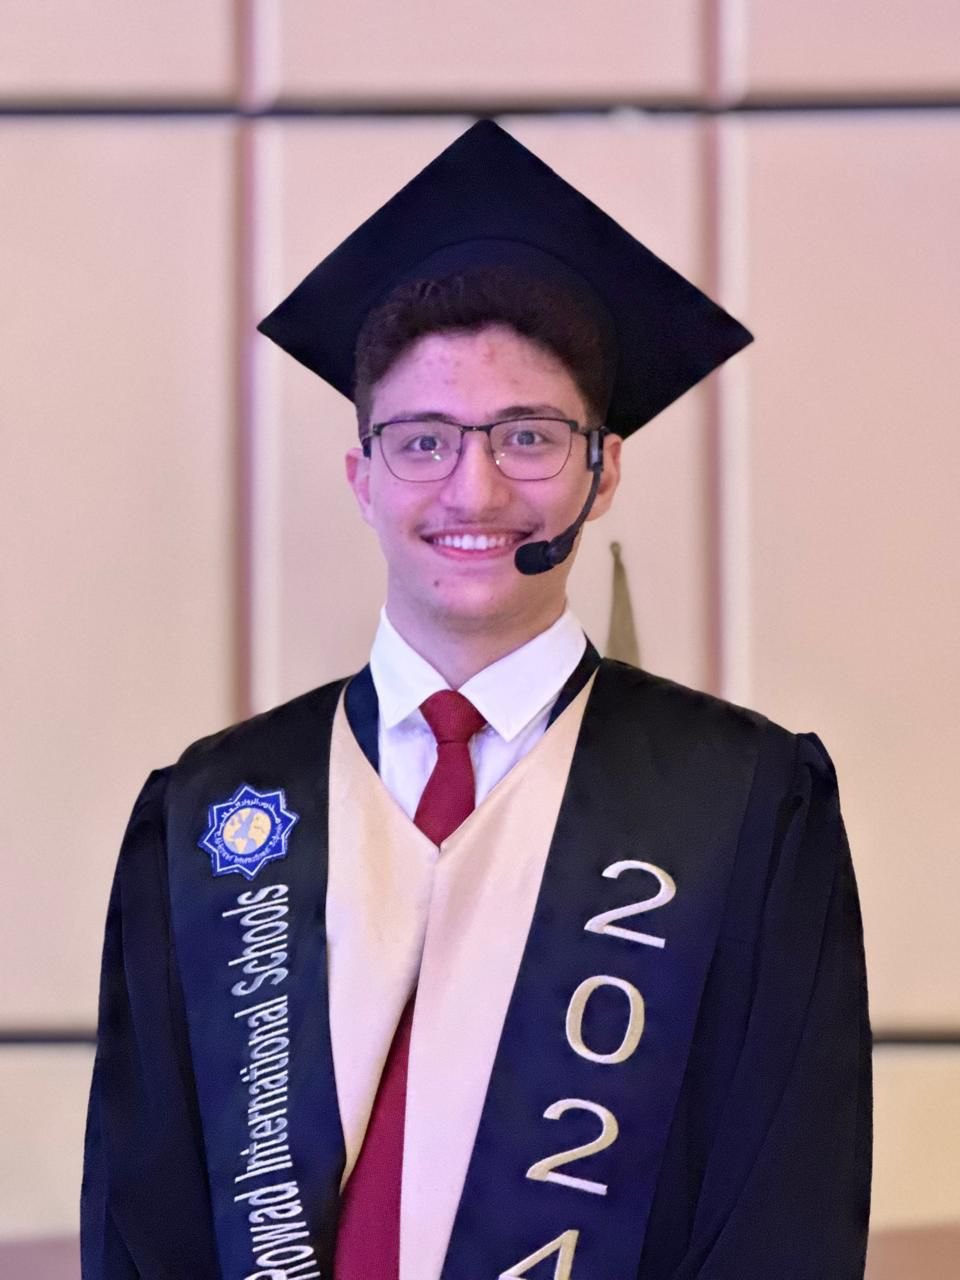
Abdullah in cap and gown with a 2024 sash and a headset microphone, hosting his own graduation ceremony. Abdullah and a classmate on stage in graduation robes, both wearing 2024 sashes. Hands reaching across a table covered in motherboards, CPU coolers and screwdrivers during a PC-building workshop. Abdullah and a friend in suits, taking a selfie on a sunlit street.

Off the clock

The other half

I game, and I run the servers I game on — which is where the networking and Linux on my skills list actually came from. Nothing teaches you DNS and port forwarding like a friend saying they can’t connect.

I cook, a lot. I like bikes. And I am genuinely interested in the business side of engineering, not just the build — writing the ROBONEXUS proposal and walking away with ₩6,000,000 was one of the more satisfying things I have done, and it was not a technical problem.

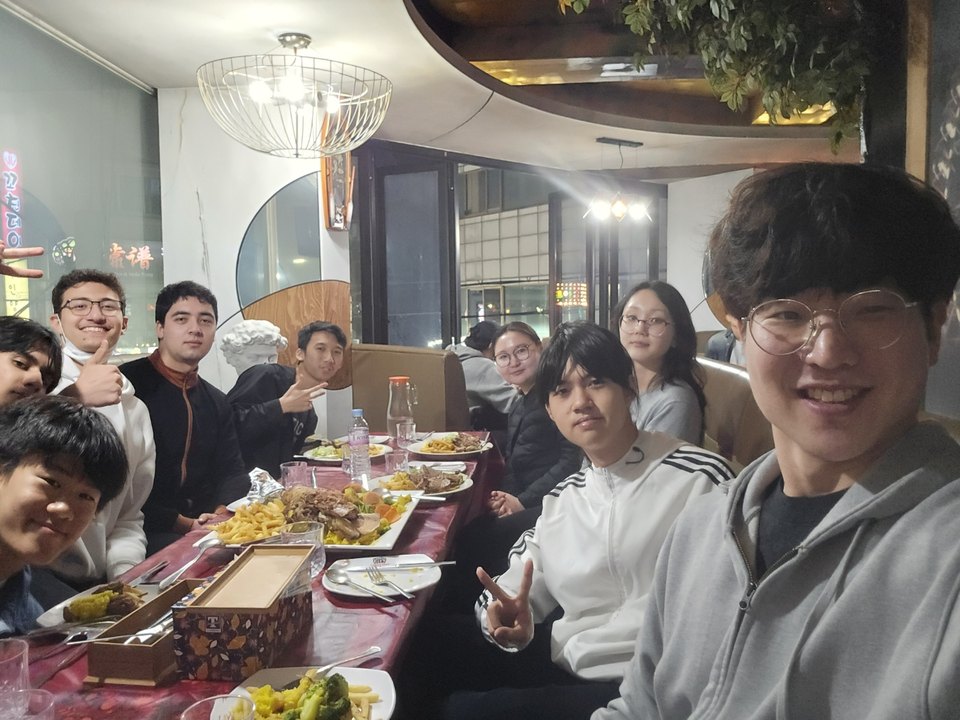
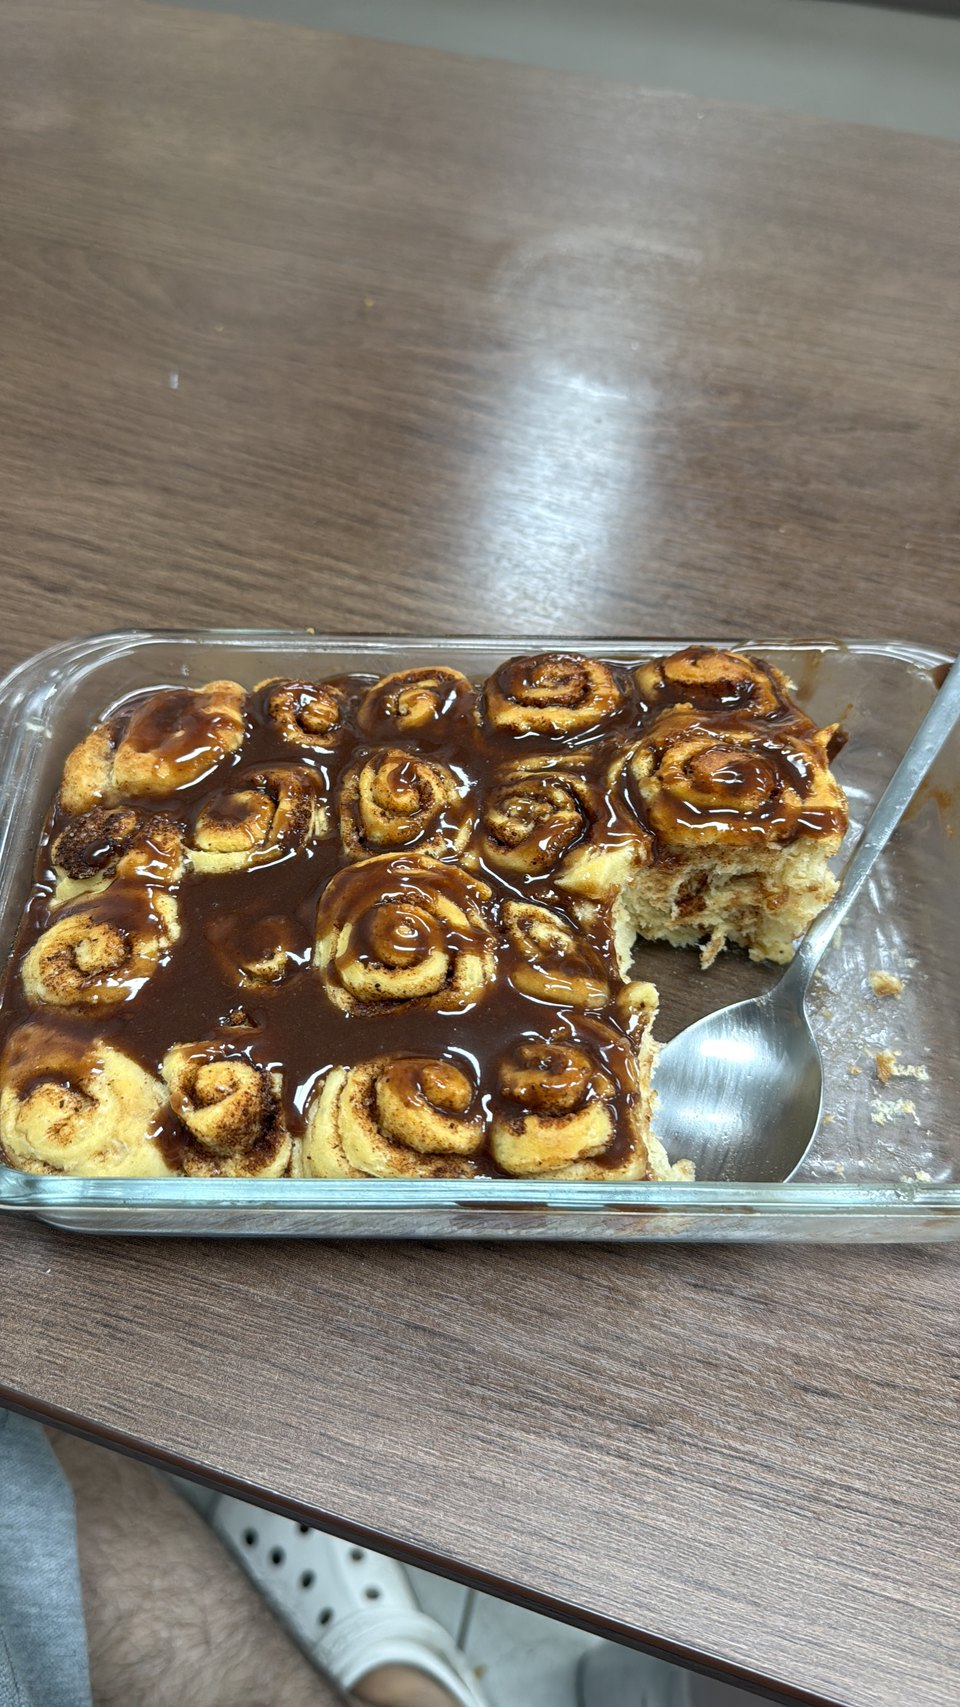
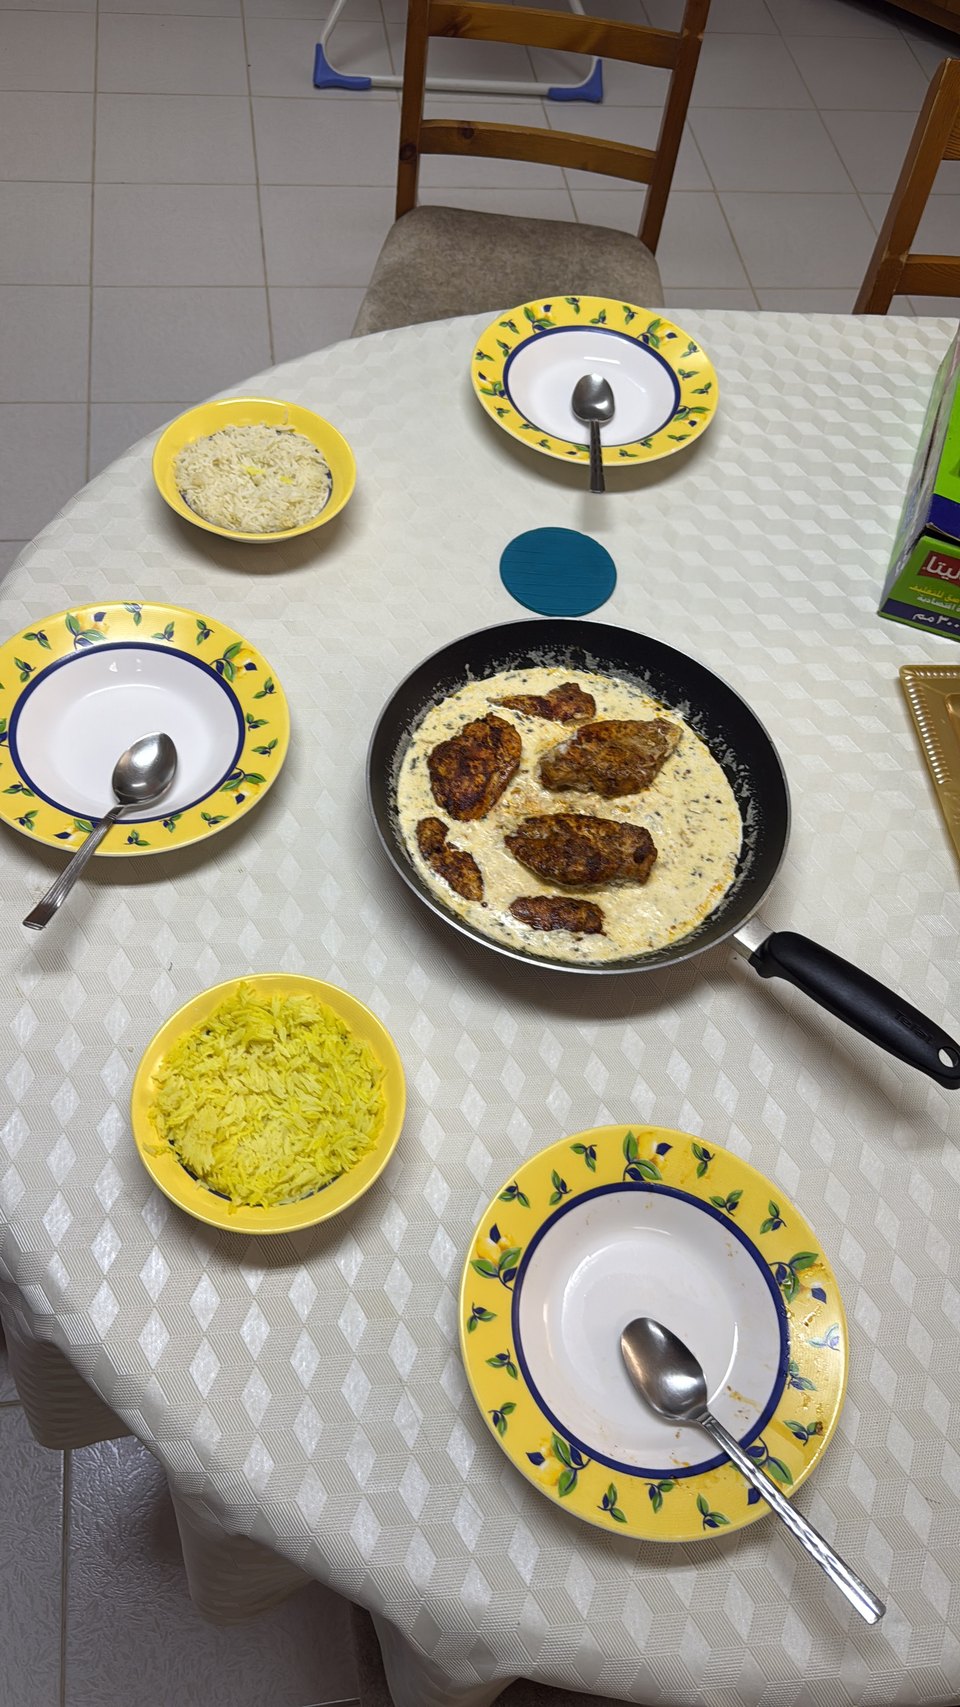
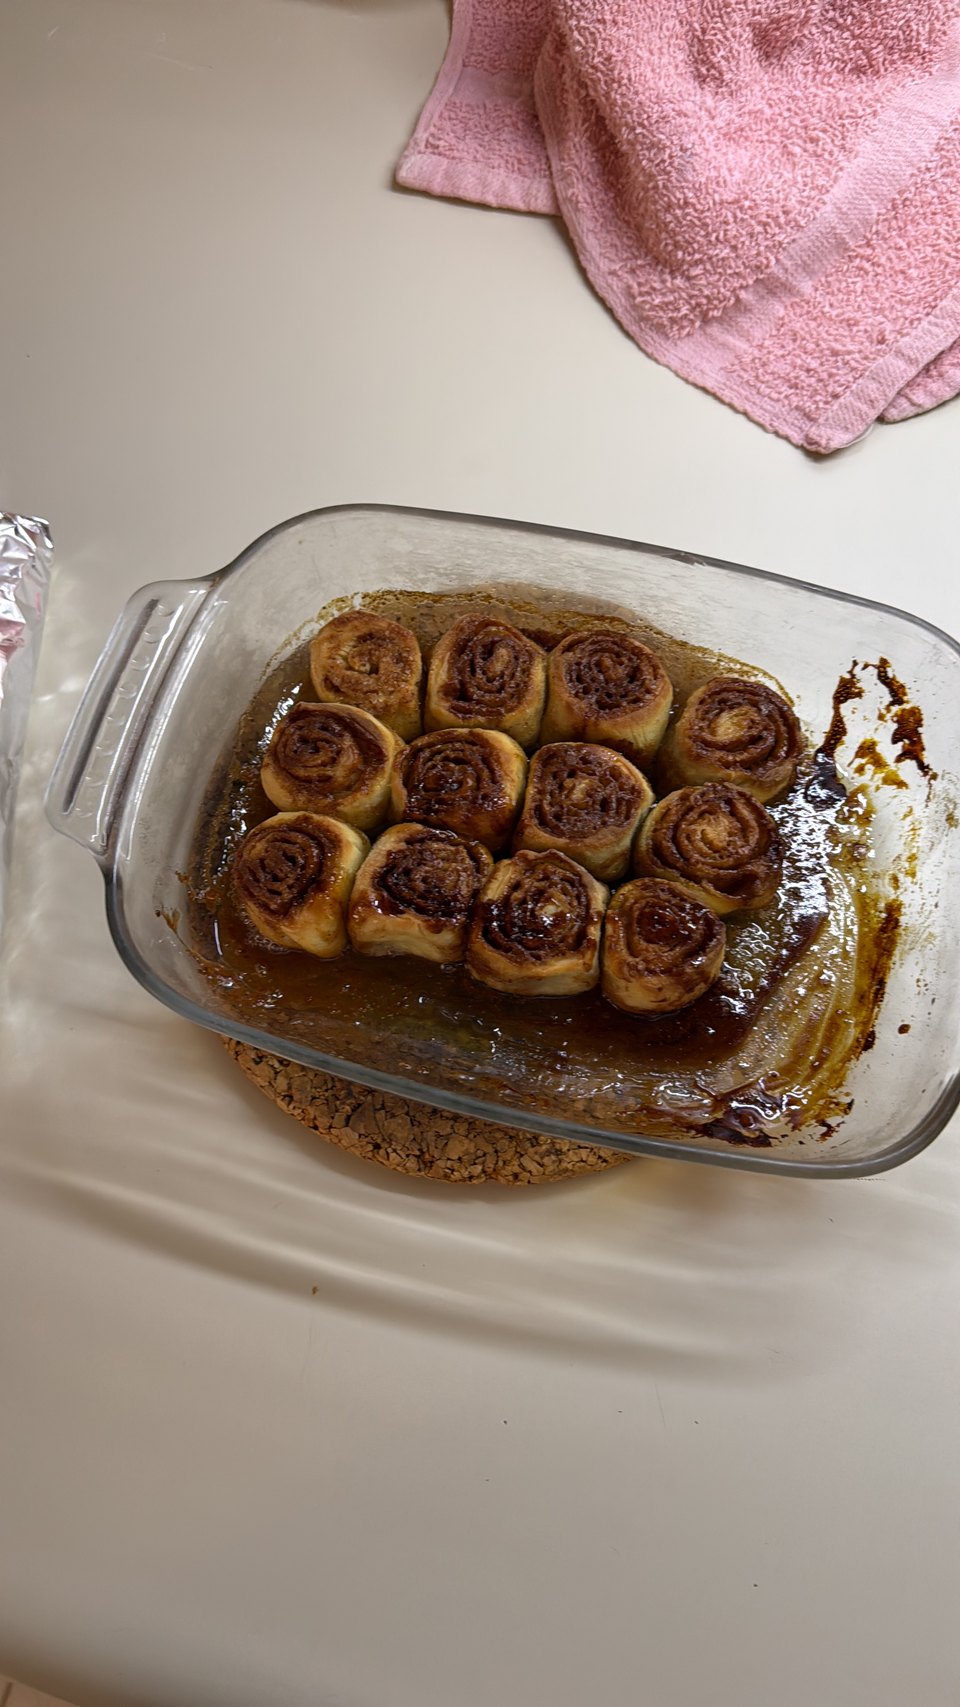
Abdullah and six friends crowded around a table of food, all pulling faces at the camera. A flatbread baked at home, blistered and cheese-topped, fresh out of the pan. Abdullah in a commercial kitchen with two colleagues, trays of prepped food in front of them. A long table of shared dishes with a dozen friends around it. A tray of homemade cinnamon rolls under caramel sauce, one already lifted out. Abdullah standing with his fat-tyre e-bike on a campus path in winter. Abdullah in front of a waterfall on a rocky hillside. A beach at sunset with the tide running out, low sun across the water. A table laid with rice, stew and side dishes on patterned plates, cooked at home. A glass dish of cinnamon rolls in caramel sauce, straight out of the oven. Abdullah copying the pose of a painted warrior statue at the gate of a Korean palace. Abdullah and two friends in hairnets and gloves behind a food stall under a marquee.

Get in touch

Open to internships & research

I am looking for robotics internships and research positions — perception, navigation and autonomy on real hardware. If you have something running in the field, I would like to hear about it.

Download CV